A survey rover, farm machine, or drone may need centimeter-level positioning far beyond the practical reach of one local base. Standard PPP offers broad coverage, but its initialization can take time. Local RTK initializes quickly, yet its strongest performance stays tied to nearby reference infrastructure. PPP RTK GNSS bridges those two operating models. It combines precise satellite information with regional atmospheric corrections so compatible receivers can initialize faster while working across a larger correction-service area.
Where PPP-RTK Fits in High-Precision GNSS
High-precision GNSS methods solve different parts of the same problem: satellite errors, atmospheric delay, receiver bias, and carrier-phase ambiguity. PPP-RTK sits between local relative positioning and wide-area precise positioning.
Traditional RTK compares a rover with a nearby reference station or network-generated virtual reference. Because many error sources are similar over a short distance, differencing removes much of the common error and lets the rover fix carrier-phase ambiguities quickly. The tradeoff is geographic dependence: correction quality usually falls as the rover moves farther from the reference network model or outside its service footprint.
PPP takes another route. A single receiver applies precise satellite orbit and clock products and estimates remaining errors in its own filter. It does not need a local base station, which makes it attractive for broad or remote operations, but standard PPP can require many minutes to converge after startup or a substantial signal interruption.
PPP-RTK adds regional information to the PPP model. Along with precise satellite orbit, clock, and bias corrections, the service provides atmospheric information for the user area. That extra regional layer helps the receiver separate ionospheric, tropospheric, and ambiguity terms sooner. The result is a positioning architecture designed for rapid initialization, wide-area service, and centimeter-class accuracy under good satellite visibility and correction coverage.
How PPP-RTK Corrections Work
PPP-RTK does not rely on one correction value. It separates major GNSS error sources so the rover can apply the right information at the right scale and resolve its position more quickly.
Precise Satellite Orbit, Clock, and Bias Corrections
GNSS satellites broadcast navigation data, but high-precision positioning benefits from more accurate estimates of each satellite’s orbit and clock. A PPP-RTK service derives these products from a tracking network and sends corrections that refine the broadcast values. Phase and code bias products are also important because carrier-phase measurements contain hardware-dependent offsets that must be handled consistently before integer ambiguities can be fixed.
Orbit errors change relatively slowly, while clock terms need more frequent updates. A rover applies the incoming corrections to its raw observations before estimating position. This shared satellite layer can serve users over a wide region because satellite orbit and clock errors are largely common to receivers observing the same satellites.
Regional Ionospheric and Tropospheric Corrections
The atmosphere is the part that gives PPP-RTK its regional character. Charged particles in the ionosphere delay GNSS signals in a frequency-dependent way, while water vapor and air pressure in the troposphere create additional path delay. Those effects vary with location, time, satellite elevation, and weather conditions.
A regional reference network estimates these delays at known points. The service can distribute grid values or model parafeet that a rover interpolates for its own location. Good atmospheric corrections reduce the number of unknowns the rover must estimate at startup, which is one reason PPP-RTK can initialize much faster than standard PPP. Dense, well-monitored regional infrastructure is especially valuable during periods of strong ionospheric activity or rapidly changing weather.
SSR and OSR Correction Representations
PPP-RTK is commonly associated with State Space Representation, or SSR. SSR separates error sources into parafeet such as satellite orbit, clock, signal bias, and atmospheric states. The rover reconstructs the corrected measurement model from those components. This is efficient for wide-area distribution because the same satellite corrections can serve many users, while regional atmospheric terms are supplied at the spatial resolution they need.
Conventional RTK and many network RTK services often use Observation Space Representation, or OSR. OSR packages the combined effect of several errors into corrected observations or range corrections tied to a physical or virtual reference location. Both approaches can support high accuracy, but SSR is better suited to scalable broadcast-style services because it separates the underlying error states instead of generating a user-specific virtual observation stream.
Ambiguity Resolution and Fast Initialization
Carrier-phase measurements are extremely precise, but the receiver initially does not know the whole number of signal wavelengths between each satellite and antenna. That unknown integer is the ambiguity. A float solution estimates ambiguities as real numbers; a fixed solution identifies the correct integers and normally delivers much tighter positioning.
PPP-RTK speeds this process with satellite phase-bias products plus regional atmospheric corrections. With fewer correlated unknowns in the filter, compatible multi-frequency receivers can often move to a fixed solution in seconds or a few minutes under favorable conditions. Actual initialization time still varies with satellite geometry, correction latency, receiver design, multipath, sky blockage, and the quality of the regional atmosphere model.
PPP-RTK vs RTK vs PPP
The main differences are infrastructure, initialization behavior, service area, and how corrections reach the rover. The comparison below shows where each method places its processing and network requirements.
|
Comparison point
|
PPP-RTK
|
RTK
|
PPP
|
|
Need for a Local Base Station
|
No dedicated base at the user site. Regional reference infrastructure still generates corrections.
|
Usually needs a nearby base or access to a local/network RTK service.
|
No local base station; uses precise satellite products and receiver-side estimation.
|
|
Convergence and Initialization Time
|
Often seconds to a few minutes with good atmospheric corrections and ambiguity support.
|
Often seconds after sufficient satellite lock and a reliable short-baseline correction link.
|
Commonly slower; many real-time PPP solutions need several to tens of minutes to reach their best precision.
|
|
Coverage and Scalability
|
Designed for regional or wider service areas and many simultaneous users.
|
Strongest inside the modeled network or practical baseline range around reference stations.
|
Potentially global when precise products are available, with no regional atmosphere service required.
|
|
Bandwidth and Correction Delivery
|
Compact SSR-style states can be delivered by internet, radio, or satellite service, depending on provider.
|
Often receives RTCM observation or network corrections through radio or NTRIP/cellular links.
|
Receives precise orbit, clock, and bias products; delivery may use internet or satellite broadcast.
|
Where PPP-RTK Works Well?
PPP-RTK is most useful where users need fast, repeatable high-precision positioning across more than one local worksite. Strong correction coverage and clear satellite tracking remain important operating conditions.
- Precision agriculture across dispersed fields: Regional corrections let tractors, sprayers, and guidance systems move between fields without deploying a new physical base at every site. Fast ambiguity resolution is especially useful after short stops or brief signal interruptions during daily field work.
- Surveying and construction inside a correction-service region: Crews can share one regional service across multiple jobs while keeping the same correction framework. It suits stakeout, machine control, mapping, and mobile data collection where a local base would add setup time.
- UAV mapping and inspection: A compatible drone can receive wide-area precise corrections during flight, which helps geotag imagery and navigation data consistently across larger corridors. Reliable cellular or satellite correction delivery is important when the aircraft moves between coverage cells.
- Autonomous machines that combine GNSS with onboard perception: Wide-area correction services pair well with visual, inertial, or LiDAR-based localization because each sensor covers different operating conditions. Sunseeker’s Sunseeker Elite X9 uses AONavi positioning with Network RTK and visual navigation for accurate boundary setting and route planning, illustrating how correction-assisted GNSS and onboard perception can work together in autonomous outdoor equipment.
- Mobile mapping and fleet operations: Vehicles that travel across a city, campus, utility corridor, or agricultural region benefit from one correction service rather than a separate base at each stop. Centralized correction delivery also simplifies fleet configuration when many receivers use the same service.
Conclusion
PPP-RTK extends precise GNSS beyond the practical footprint of a single local base while keeping initialization far faster than conventional PPP in well-supported regions. Its value comes from combining precise satellite products, regional atmospheric corrections, and ambiguity resolution in one scalable service. For autonomous outdoor equipment, similar correction-assisted positioning also supports consistent digital boundaries and repeatable routes. Explore Sunseeker’s robot lawn mower range to see how connected navigation is applied to routine lawn maintenance across changing schedules and service areas.
FAQs
What is the difference between RTK, PPP-RTK, and PPP-AR for agriculture?
RTK uses a nearby base or network RTK service and is well suited to farms inside that local coverage area. PPP-RTK adds regional atmospheric corrections to precise satellite products for faster wide-area initialization. PPP-AR can fix carrier-phase ambiguities with precise bias products, but without regional atmosphere corrections it generally needs more convergence time.
Is a physical RTK base station required?
A PPP-RTK user does not need to install a dedicated physical base at the jobsite. The correction provider still relies on reference stations somewhere in the service infrastructure to estimate satellite and atmospheric errors. The rover needs a compatible receiver plus access to the provider’s real-time correction stream.
What is the difference between PPP-RTK and traditional RTK for drones?
Traditional RTK usually ties a drone to a nearby base or network-generated reference and can initialize very quickly inside that coverage area. PPP-RTK distributes precise satellite and regional atmosphere states across a wider service region, which can simplify multi-site or corridor flights when the drone maintains a stable correction link and clear satellite tracking.


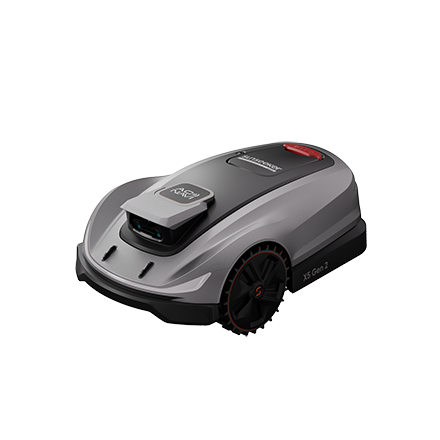
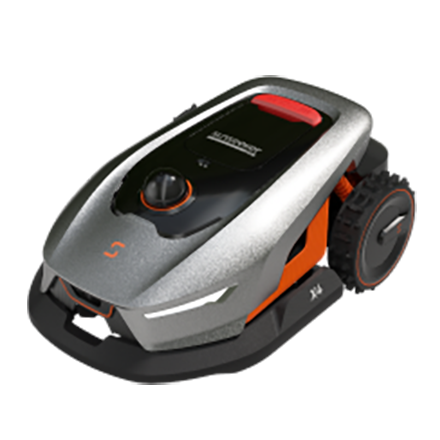
 X7 / X7 Plus Gen 2High-performance mowing for lawns up to 1.5 Acres.USD 2499 / USD 2999