A survey crew can finish one site, drive across town, and need precise coordinates again without setting another base station. The same issue appears in agriculture and autonomous equipment: accurate positioning is useful, but installing and managing a local reference at every work area adds setup time.
NRTK addresses that problem with a permanent GNSS reference network and real-time internet delivery. The sections below explain what changes compared with single-base RTK, how corrections reach a rover, where the method fits well, and what users should verify before trusting a network service.
NRTK Meaning and What Changes From Single-Base RTK
Traditional RTK can be highly precise, but its performance is tied closely to the rover’s distance from a single reference. NRTK changes that geometry by treating several permanent stations as one correction network.
NRTK means Network Real-Time Kinematic. Multiple fixed GNSS stations send observations to network software, which estimates spatially varying errors across the service area. These include atmospheric effects and other distance-related biases. The service then produces corrections for rovers operating inside that modeled region.
A single-base setup is useful when the operator controls a nearby reference and has a reliable radio or data link. As the rover moves farther away, conditions at the base and rover become less alike. NRTK uses several known stations to model those regional changes, so one service can support work across a broader area without relocating a physical base.
The practical changes are easiest to see in daily operation:
- Users connect to shared reference infrastructure instead of occupying and protecting a local base point for every job.
- Network software can create a virtual reference near the rover or provide another supported network correction model.
- Corrections usually travel over an IP connection such as cellular or Wi-Fi rather than a short-range base radio.
- Account access, mountpoint, RTCM format, reference frame, and receiver compatibility become essential setup details.
How Network RTK Corrections Reach the Rover
A rover does not simply connect to the nearest antenna and receive finished coordinates. The network first combines reference observations, then serves a correction stream that the rover can apply in real time.
Reference-Station Networks
An NRTK service begins with fixed GNSS reference stations at accurately surveyed positions. Each station continuously tracks satellite signals and sends observations to a control center. Because the station coordinates are known, the network can estimate how GNSS errors behave across the region. Good coverage geometry matters: a rover generally performs best inside a well-observed part of the network rather than beyond its edge. Operators also monitor station health, data gaps, clocks, and signal quality so a faulty reference does not silently shape the correction stream.
Network Processing and Virtual Reference Solutions
The server uses several stations to model distance-dependent GNSS errors. One common method is a Virtual Reference Station, or VRS. The rover provides an approximate position, and the network generates correction data that represents a reference close to that location. The receiver can then process the stream much like short-baseline RTK. Other services may use MAX, i-MAX, MAC, or FKP approaches. Because mountpoints can provide different network products, message sets, or reference frames, users should select the one specified for their receiver and project.
NTRIP and the Internet Connection
NTRIP stands for Networked Transport of RTCM via Internet Protocol. It delivers GNSS correction data; it does not create the NRTK correction itself. An NTRIP client in the receiver, controller, modem, or app logs in to a caster and selects a mountpoint. For VRS-style service, the client commonly sends an approximate rover position, often as an NMEA GGA message, and receives RTCM corrections in return. Stable internet access is therefore part of the real-time positioning chain, alongside clear satellite reception at the rover.
Where NRTK Is Most Useful
NRTK is most valuable when precise GNSS work has to move across a region without rebuilding local reference infrastructure at every stop. Several field workflows benefit strongly from that shared correction service.
Surveying and Construction Across Multiple Sites
Survey and construction crews can use NRTK for topographic pickup, stakeout, machine checks, and other real-time tasks at many sites. Once the receiver has the correct credentials and project settings, crews can connect without placing a base over a known point each morning. That saves setup time and removes the need to guard a local base. Normal checks still apply: verify known control, watch the solution type and precision estimates, and confirm the project datum or localization before storing critical points.
Precision Agriculture and Autonomous Machines
Repeatable GNSS guidance is useful for tractors, sprayers, field robots, and other machines that follow planned paths over large areas. Network corrections can reduce the need for a user-operated local base where a suitable service already covers the property. The machine still needs compatible GNSS hardware plus its own steering, perception, or control system.
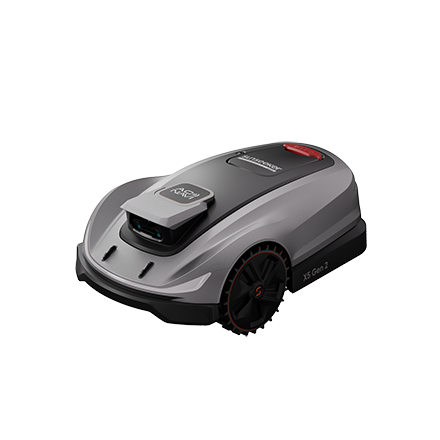
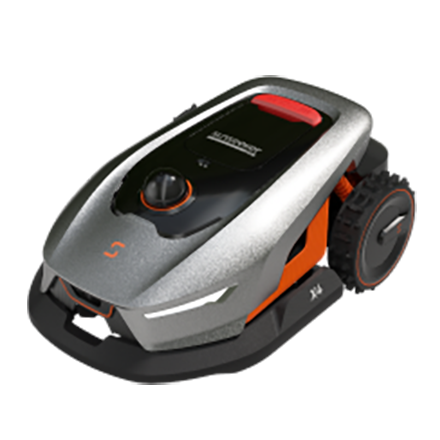
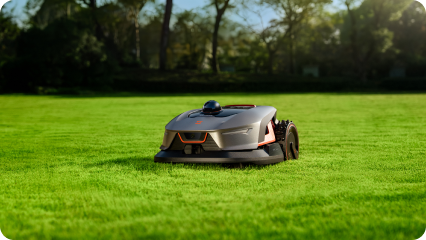
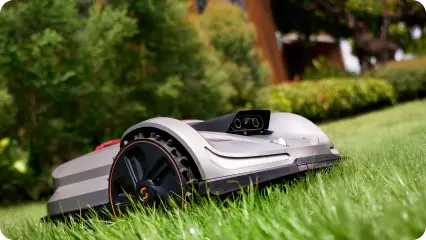
For large-lawn maintenance, the Sunseeker Elite X9 uses AONavi positioning with integrated 4G connectivity on the current X9 platform, supporting precise mapping and route planning without a separate antenna-station installation. Its multi-camera perception works alongside satellite positioning around trees, narrow passages, and other challenging parts of a property. The result is simpler setup across a large established lawn and steadier route planning during routine mowing.
Mobile Work Across a Wide Service Area
NRTK also suits crews that collect assets or inspect infrastructure across a city, county, or utility territory. A mobile GIS team can move among valves, poles, signs, drainage structures, and construction records while keeping one correction account and receiver configuration. This is more practical than transporting a local base for every short stop. Teams should still test representative sites because service quality can weaken near the network boundary, in remote areas with poor data coverage, or where buildings and trees block satellite signals.
NRTK Limitations and What to Verify Before Use
Network corrections remove some local-base work, but they add dependencies on external infrastructure and configuration. A reliable setup comes from checking the service, receiver, coordinate settings, and live quality indicators together.
Network Coverage and Cellular Availability
Two kinds of coverage must be good at the same time. The rover needs adequate GNSS satellite visibility, so trees, buildings, walls, and reflective surfaces can still cause blockage or multipath. It also needs a working internet path to the correction caster. Before deployment, test the actual work area and check login speed, fixed-solution time, correction age, reconnection behavior, and performance near site edges. For critical work, plan a fallback such as another network, a local base, or raw observations for later processing.
Receiver, Correction Format, and Mountpoint Compatibility
A subscription does not guarantee that every rover can use every stream. Confirm that the receiver supports the network method and the RTCM messages supplied by the selected mountpoint. Modern services often use RTCM 3.x messages, including Multiple Signal Messages, but exact message sets and supported constellations vary. Also verify server address, port, credentials, mountpoint name, and any required GGA output. If several mountpoints look similar, use the provider’s documentation instead of choosing only by name or apparent distance.
Reference Frame, Latency, and Quality Control
The service reference frame and epoch must agree with the coordinates expected in the project. A stable fixed solution can still be offset if the network, site calibration, and design data use different coordinate realizations. Check a known point before production work, especially when combining NRTK observations with existing control. During field use, watch correction age, satellite geometry, ambiguity status, and horizontal and vertical precision estimates. A jump from near-real-time corrections to several seconds of age is a useful warning that the data link may be weakening.
Conclusion
NRTK extends real-time GNSS positioning across a wider service area by combining permanent reference stations, network processing, and an internet-delivered correction stream. Good results still require compatible hardware, solid satellite visibility, the correct mountpoint, and a matching reference frame. For connected lawn care, a robot lawn mower that pairs Network RTK with onboard perception shows how the same positioning model can support precise, wire-free navigation while keeping setup simpler for routine lawn maintenance.
FAQs
What is Network RTK?
Network RTK is a real-time GNSS positioning method that uses observations from multiple fixed reference stations. Network software models regional errors and sends a rover a VRS-style or other network correction stream. With compatible equipment, suitable coverage, and good satellite visibility, it can support centimeter-level positioning across a broader area than a typical single-base setup.
Does Network RTK require NTRIP?
No. NTRIP is a widely used internet delivery protocol for GNSS corrections, but it is not the NRTK calculation method itself. A provider can generate Network RTK corrections and deliver them through another supported data channel. Many current services use NTRIP because it supports authenticated caster connections, mountpoints, and standard RTCM correction streams.
Is Network RTK better than a local RTK base station?
Each setup fits different work. NRTK is convenient across a broad service area because users do not need to deploy a base at every site. A local base gives the operator direct control and can work where network or cellular service is unavailable. Accuracy and reliability still depend on geometry, environment, equipment, configuration, and quality checks.


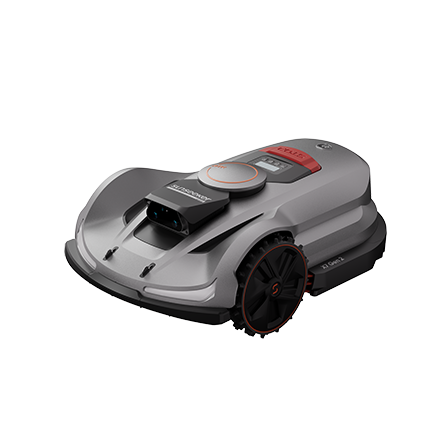
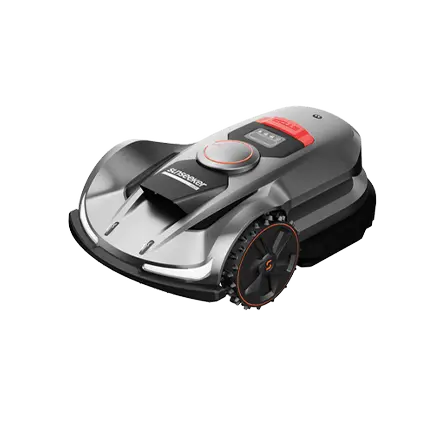
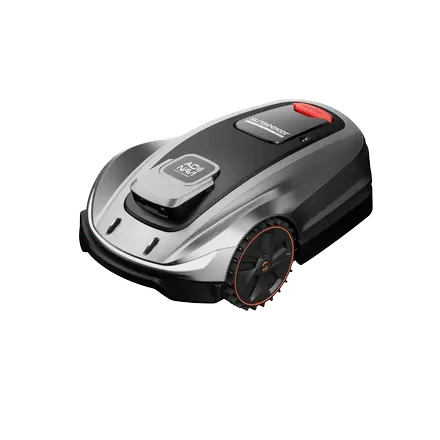
 X7 / X7 Plus Gen 2High-performance mowing for lawns up to 1.5 Acres.USD 2499 / USD 2999